Signal Flow Diagram
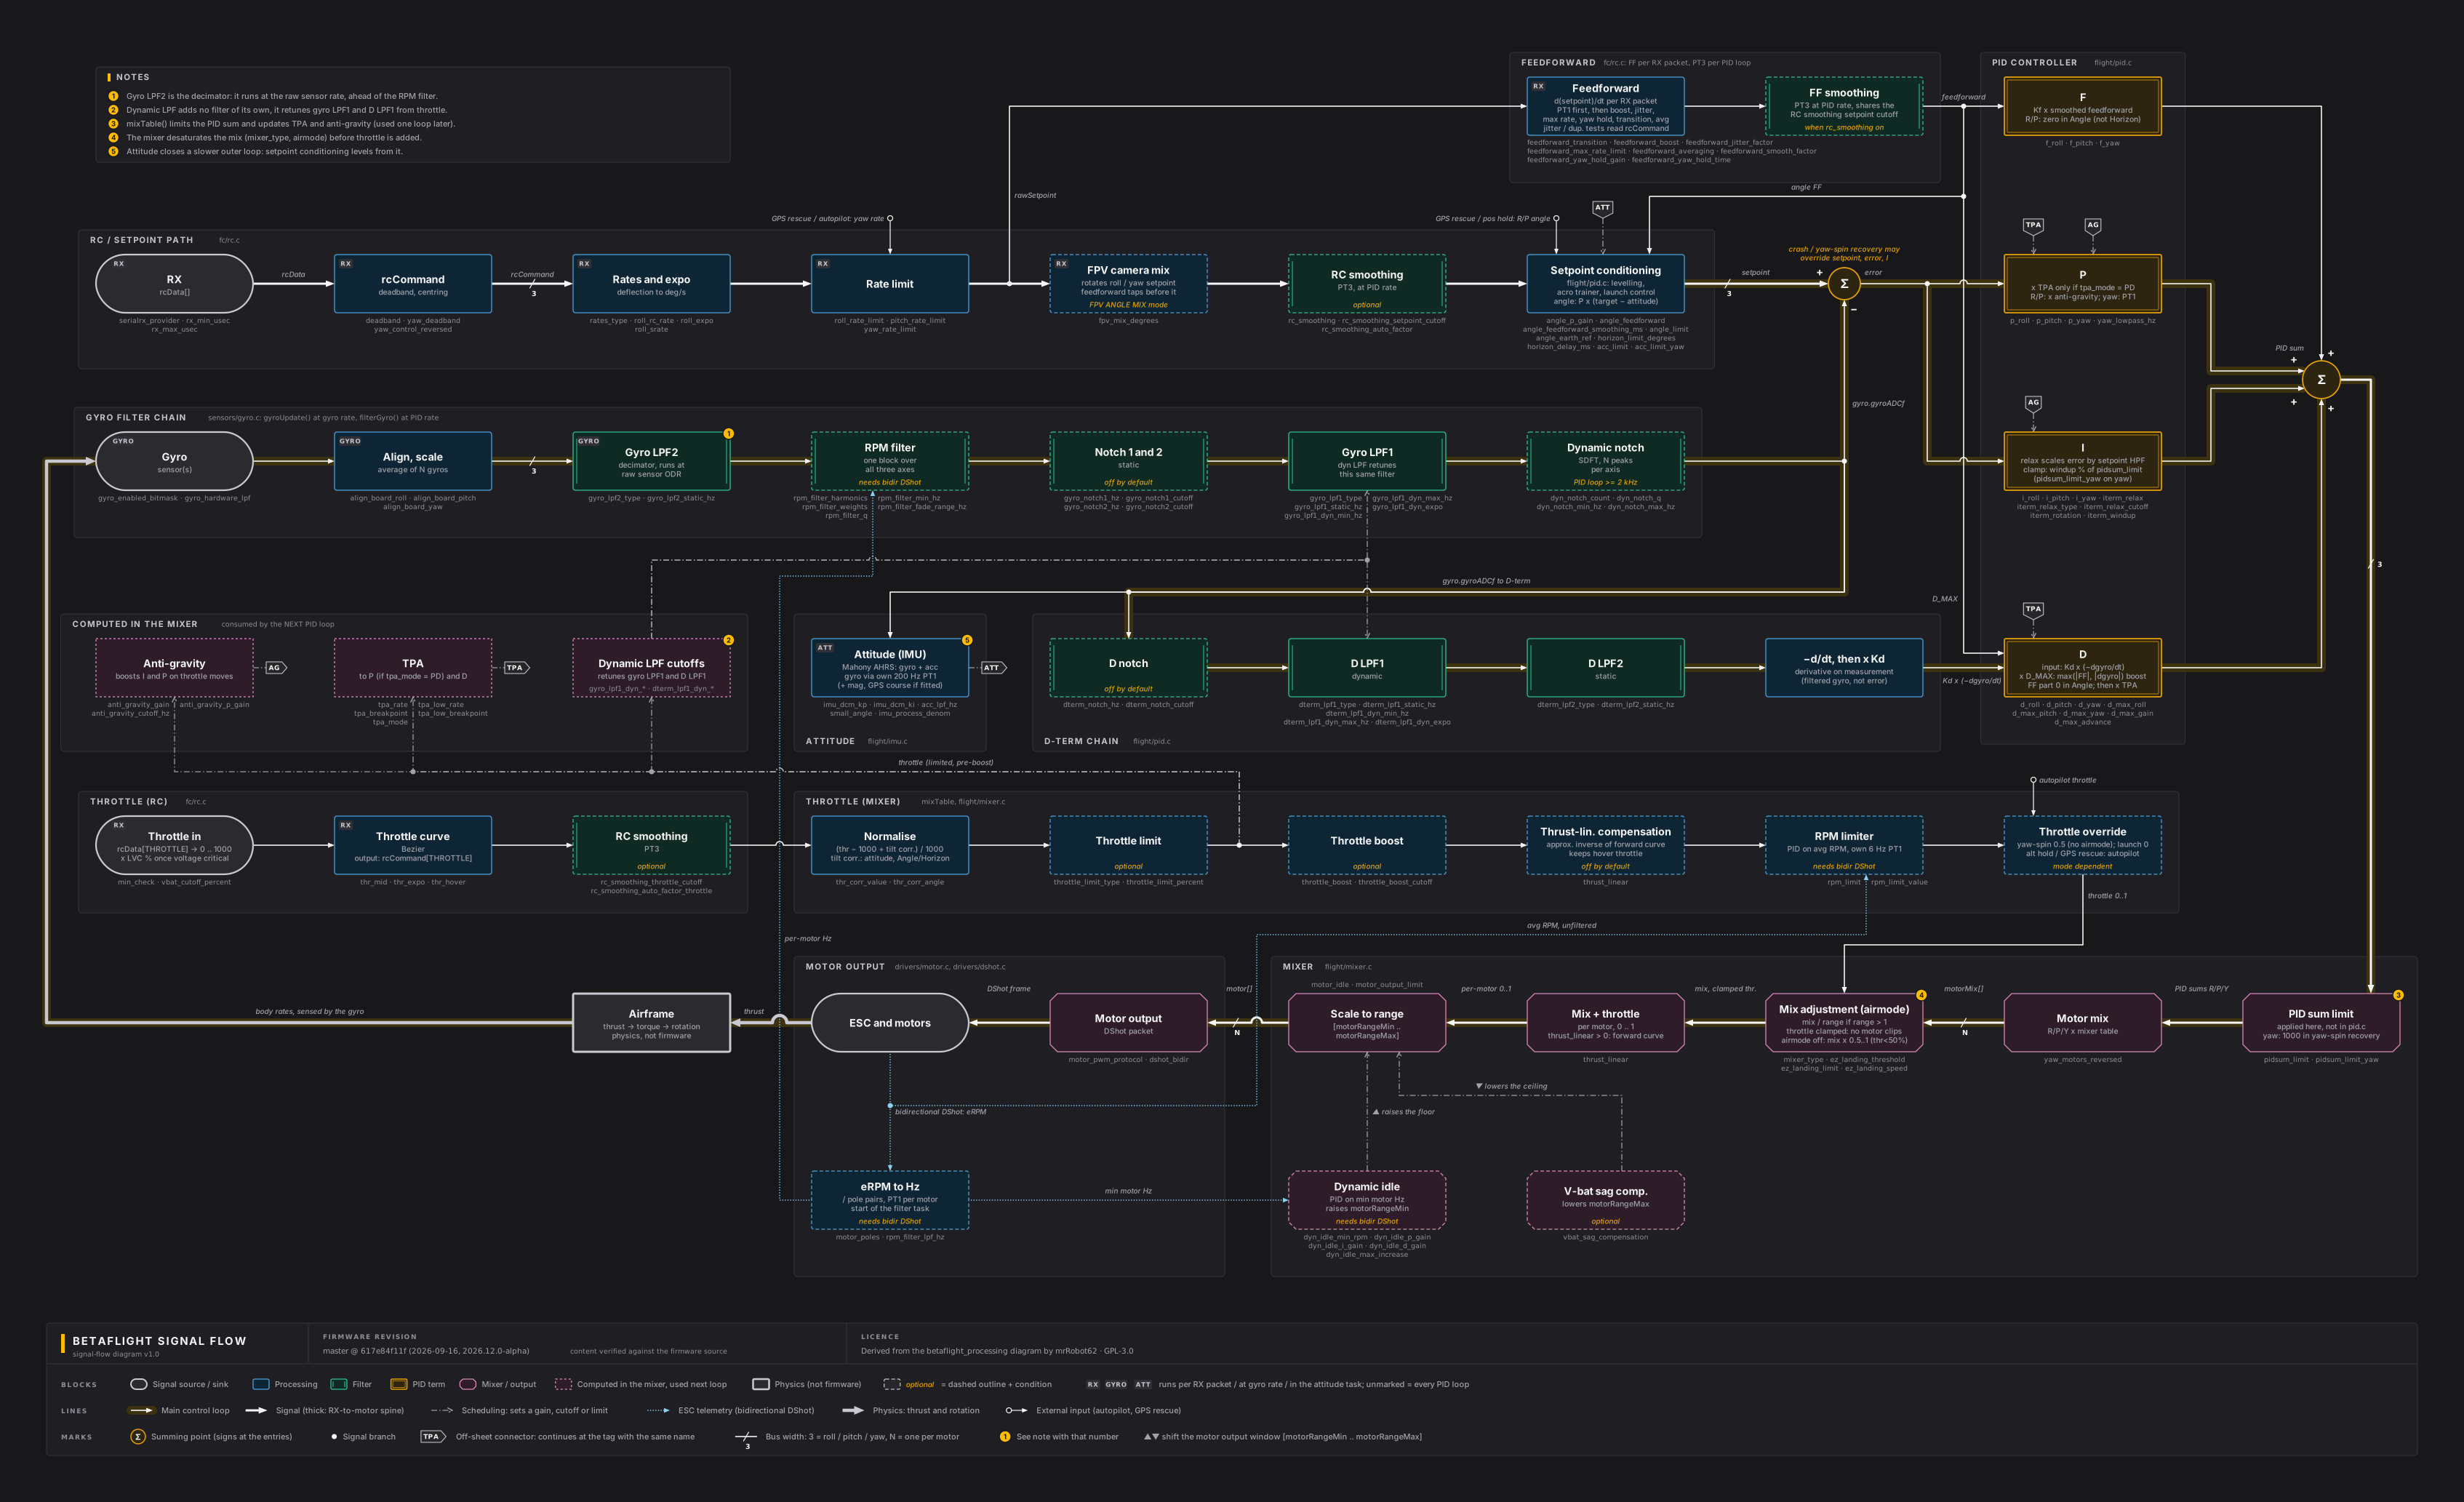
How a stick movement becomes a motor command, and how the gyro measurement gets back to the PID controller. The diagram covers the multirotor control loop: RX through RC smoothing, rates, feedforward, the PID controller, the mixer and the motor output, together with the gyro and D-term filter chains, the throttle and RPM feedback paths, the attitude (Angle/Horizon) outer loop, and the airframe that closes the physical loop back to the gyro.
It reflects master @ 617e84f11f (2026-09-16, 2026.12.0-alpha), and was drawn from the
firmware source.
Editing
The four SVGs (signal-flow-{light,dark}.svg and signal-flow-overview-{light,dark}.svg) are
generated — do not edit them by hand. The diagram is defined as a plain-JavaScript
model in tools/signal-flow/model.mjs
(blocks, lanes, groups, edges, junctions and CLI parameter callouts). layout.mjs computes the
coordinates and orthogonal edge routes from it, and npm run signal-flow validates the geometry
(check.mjs) and re-renders both themes (render.mjs). Because light and dark come from the same
model, they cannot drift apart. No external tools or dependencies are involved — the generator is
dependency-free and the SVGs are self-contained.
npm run signal-flow:preview serves a live preview that re-renders on every save. npm run check
and the pre-commit hook fail when the committed SVGs are out of date with the model (fresh.mjs). On this page the SVG is
inlined by the DiagramViewer component (src/components/DiagramViewer), which hides the
data-layer="parameters" group until the reader zooms in far enough to read it. The Simplified view
is a second, hand-arranged model of the same loop, ten modules and no crossing lines, in
tools/signal-flow/overview.mjs.
It uses the same layout engine, checks and renderer, and is written to
signal-flow-overview-{light,dark}.svg. When a module changes in model.mjs, update its one-line
summary there too.
Credits
Derived from the betaflight_processing diagram by @mrRobot62, with earlier layout work by @hdavid. Licensed under the GNU General Public License v3.0.